
Isaac Sim Boot Order
There is one wall that almost everyone writing Isaac Sim code hits at least once.
import omni.isaac.core   # ❌ ModuleNotFoundError / crash
from isaacsim import SimulationApp
The package is installed, but the import fails. The reason is simple but absolute — Isaac Sim's omni.* modules only exist after the Kit runtime is running. The ordering constraint is enforced at the runtime level, not the code level.
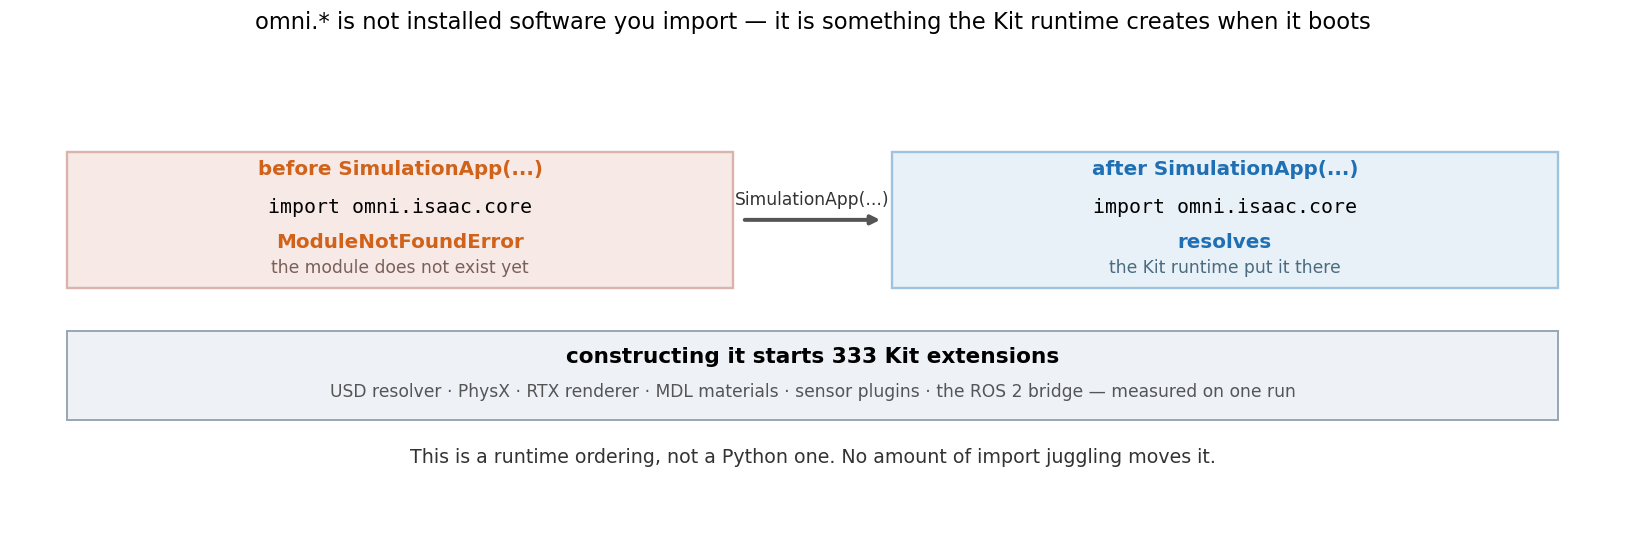 The difference between left and right is not the code but the runtime. Constructing SimulationApp(...) brings up 333 Kit extensions — USD resolver, PhysX, RTX renderer, MDL materials, sensor plugins, the ROS 2 bridge — and only then does omni.* exist. The extension count was measured on one of our runs.
What that number says is not "this is heavy" but "an import here is not a file lookup." omni.* is not a package sitting on disk; it is something the runtime placed there, which is why reordering imports never helps.
SimulationApp Is Step One — Everything Else Comes After
The correct sequence:
from isaacsim import SimulationApp
sim = SimulationApp({"headless": True})   # ← Boot the Kit runtime. This is step 1.

# Only after this line are omni.* imports available
import omni
from isaacsim.core.api import World
The moment SimulationApp(...) is instantiated, the Omniverse Kit runtime loads into memory. Only then do the omni.* extensions that provide USD, PhysX, and RTX become available. Importing omni.* before that is looking for modules that do not yet exist.
Rendering diagram…
Why This Order Matters — world.reset() Is a Second Hard Boundary
The boot sequence has a second critical boundary: world.reset(). PhysX locks in collision filters, FixedJoints, and GPU dynamics settings at reset time. This means many configuration steps must be complete before reset is called.
| Must happen before reset | Must happen after reset |
|---|---|
| FixedJoint creation (created after reset freezes all joints) | GPU dynamics enable |
| broadphase collision filter setup | physics step callback registration |
| fixed base configuration | trajectory recording start |
In imSim, creating a FixedJoint after reset caused every joint to freeze (Test #8 failure). Moving it before reset fixed the issue (Test #9). The strict pre/post-reset discipline exists for exactly this reason.
imSim's Deliberate Choice — Always Fresh, Never Daemon
Since booting is expensive (tens of seconds), it is tempting to keep the simulator running and reuse it across multiple runs. imSim deliberately discarded this approach (daemon mode).
Rendering diagram…
- Rationale: accumulated stage/PhysX state between runs breaks reproducibility. A clean start is fundamental for a validation platform.
- The daemon code path is disabled — only Fresh mode is ever used in practice.
- The cost is per-run boot time, which is exactly why getting the boot sequence right matters in production.
In production, a standardized boot script always launches Isaac Sim to guarantee the correct Python and ROS2 (Jazzy) environment.
In a nutshell
📌
SimulationAppmust be the very first step in Isaac Sim. The Kit runtime must be running beforeomni.*exists.world.reset()is a second hard boundary that locks in physics state. imSim uses Fresh mode exclusively — one clean boot per run — to guarantee reproducibility.
References
See standard test results with videos and verdict evidence on the imSim Portal.
View public results →